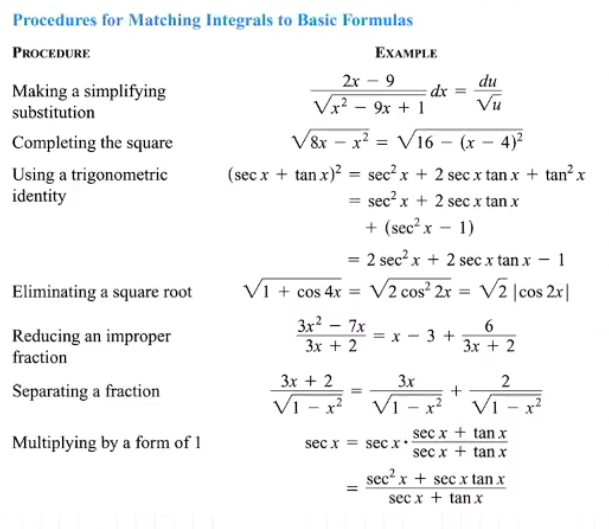
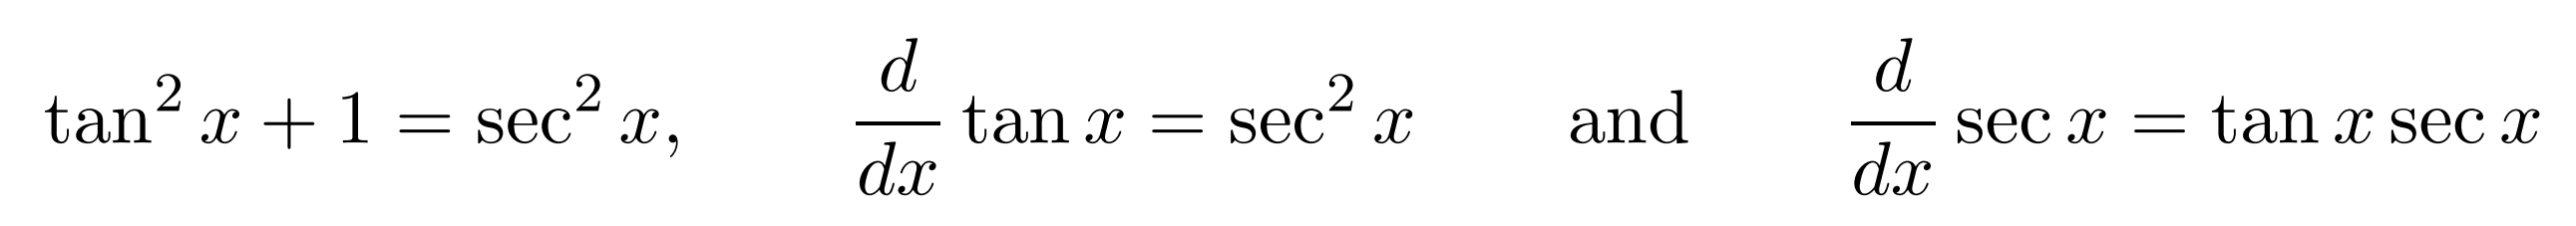Therefore, the integral is 0 — no heavy algebra required. In fact, ∫0πsinmxsinnxdx=0 whenever m and n are distinct positive integers (and the same happens for cosmxcosnx); basically the two waves are "orthogonal" over a full period, which is the starting point of Fourier series in second year. Checking whether the multiple-angle terms vanish at the limits before grinding through the algebra can save you a lot of time in an exam.
For non-obvious trigonometric reductions, you're more likely to just use integration by parts.
A reduction formula expresses an integral In that depends on a parameter n in terms of a 'smaller' integral of the same type (usually In−1 or In−2). Once you have one, big powers get knocked down step by step until you land on a base case like I0 or I1, which has to be computed directly. Occasionally an identity alone does the job, as in the first example below; every other derivation in this section needs integration by parts.
Example. Suppose that In=∫0π/4tannxdx whenever n≥0. Show that
In=n−11−In−2∀n≥2,
and hence evaluate ∫0π/4tan6xdx.
By the identity tan2x=sec2x−1,
Therefore, ∫0π/4tan6xdx=1513−4π. It is important to remember that the base case I0 must be evaluated directly, since the reduction formula is only valid when n≥2.
using cos2x=1−sin2x in the third line. Gathering the In terms on the left-hand side gives
nIn=−sinn−1xcosx+(n−1)In−2,
and dividing both sides by n gives the result. ■
Basically, you peel one factor of sinx off to integrate by parts, and the Pythagorean identity smuggles In back onto the right-hand side; "solving for the integral" is what produces the formula. It is the same trick used for ∫excosxdx. Swapping the roles of sin and cos gives the analogous formula
∫cosnxdx=ncosn−1xsinx+nn−1∫cosn−2xdx
Over [0,2π] the boundary term vanishes at both ends (since sin0=0 and cos2π=0), so both formulae collapse to
∫0π/2sinnxdx=nn−1∫0π/2sinn−2xdx
and identically for cosnx.
Example. Evaluate ∫0π/2sin5xdx.
Applying the boxed formula twice,
This is exactly what the double-angle identities of 2.1 would give (up to trig identities), but with far less algebra; for something like sin8x the reduction formula is basically the only sane option.
Therefore, the integral equals 5123π. Do not forget that the recursion bottoms out at I0,0=∫0π/2dx=2π, which must be evaluated directly. As a sanity check, the substitution x↦2π−x swaps sin and cos, so Im,n=In,m; evaluating ∫0π/2cos6xsin4xdx gives the same 5123π.
Nothing about reduction formulae is specifically trigonometric; any integrand with a power of n in it is fair game, and exam questions like using ex or lnx here.
Example. Suppose that In=∫01xne−xdx. Show that
In=nIn−1−e1∀n≥1,
and hence evaluate ∫01x3e−xdx.
Integration by parts with u=xn, v=−e−x, u′=nxn−1 and v′=e−x gives
This one connects back to the tan and sec section of 2.1; powers of sec appear constantly after a x=atanθ substitution (see 2.3), so it is worth knowing how to derive this.
Example. Show that if In=∫secnxdx, then
In=n−1secn−2xtanx+n−1n−2In−2∀n≥2,
and hence find ∫sec4xdx.
Write secnx=secn−2xsec2x and integrate by parts with
uu′=secn−2x=(n−2)secn−2xtanxv=tanxv′=sec2x,
where u′ comes from dxdsecx=secxtanx; differentiating a power of sec conveniently keeps everything in powers of sec and tan. Then
As a short remark: reduction formulae are the key ingredient in a famous proof that π is irrational. Assuming π=qp for positive integers p and q, one defines In=n!q2n∫−π/2π/2(4π2−x2)ncosxdx, proves the reduction formula In=(4n−2)q2In−1−q4π2In−2 by two applications of integration by parts, and deduces by induction that every In is an integer. But since n!an→0, we also get 0<In<1 for large n — a contradiction. This is [X] (extension) material, so it is not examinable.
There is no systematic way of finding the right substitution for a general integral; however, integrals containing the square root of a quadratic (i.e. surds of the form ±x2±a2) almost always yield to a trigonometric or hyperbolic substitution. The table below tells you which one to try.
Expression in integrand
Trigonometric substitution
Hyperbolic substitution
a2−x2
x=asinθ
x=atanhθ
a2+x2
x=atanθ
x=asinhθ
x2−a2
x=asecθ
x=acoshθ
Basically, each substitution is chosen so that a Pythagorean-type identity turns the expression under the root into a perfect square:
Whether the trigonometric or hyperbolic option is faster depends on the particular integral, but in general the trigonometric ones are favoured because once the integration is done in θ, it is easier to restate the answer in terms of x (you just draw a right triangle).
Example. Evaluate ∫1−x2dx.
The substitution x=sinθ, dx=cosθdθ yields
using the double angle formulae for cos and then sin. To state the answer in terms of x, draw a right triangle containing the angle θ: since sinθ=1x, put x on the side opposite θ and 1 on the hypotenuse, so the adjacent side is 1−x2 by Pythagoras. Reading off the triangle, θ=sin−1x and cosθ=1−x2, hence
∫1−x2dx=21(sin−1x+x1−x2)+C.
This triangle trick is how you convert back at the end of almost every trigonometric substitution, so make sure you are comfortable with it.
Example. Evaluate ∫(4+x2)3/2dx.
Since (4+x2)3/2=(4+x2)3, this is still a surd of a quadratic in disguise, so we use x=2tanθ, dx=2sec2θdθ together with tan2θ+1=sec2θ:
Now the triangle: tanθ=2x, so put x opposite, 2 adjacent, and the hypotenuse is x2+4. Thus sinθ=x2+4x and
∫(4+x2)3/2dx=4x2+4x+C.
Example. Use the substitution x=3coshθ to evaluate ∫x2−9x3dx.
With x=3coshθ, dx=3sinhθdθ, the identity cosh2θ−sinh2θ=1 gives x2−9=9cosh2θ−9=3sinhθ. Hence
where the odd power of cosh was handled with the substitution u=sinhθ, du=coshθdθ — exactly like odd powers of cos back in 2.1. Since u=sinhθ=31x2−9,
Notice how with hyperbolic substitutions you convert back to x through the identity itself (sinhθ=31x2−9), no triangle needed. The same integral can also be done with x=3secθ; it is a good exercise to check you get the same answer.
Example. Evaluate ∫x2−6x+13dx.
The quadratic does not match the table until we complete the square:
x2−6x+13=(x−3)2+4.
This is now the a2+x2 pattern (with x−3 playing the role of x), so substitute x−3=2sinhθ, dx=2coshθdθ:
Using sinh−1t=ln(t+t2+1), the answer can also be written as ln(x−3+x2−6x+13)+K. This is a case where the hyperbolic option beats the trigonometric one: x−3=2tanθ leads to ∫secθdθ, which is doable but uglier. If the quadratic under the root has a linear term, always complete the square first; none of the standard substitutions apply until you do.
Example. Evaluate ∫014−x2x2dx.
Substitute x=2sinθ, dx=2cosθdθ, and convert the limits: when x=0, θ=0; when x=1, sinθ=21 so θ=6π. Then
Therefore, the integral equals 3π−23. When substituting in a definite integral, convert the limits of integration as well; then there is no need to convert the antiderivative back to x at all.
The punchline of this section: every rational function has an antiderivative among the elementary functions, and there is a completely systematic procedure for finding it. First, some terminology.
Note
Definition
A rational functionf is a function of the form
f(x)=q(x)p(x),
where p and q are polynomials. We say that f is proper if degp<degq, and improper if degp≥degq. A quadratic polynomial is irreducible if it has no real linear factors; equivalently, ax2+bx+c is irreducible if its discriminant b2−4ac is negative.
Basically, proper means bottom-heavy (like 72) and improper means top-heavy (like 79); just as 79=1+72, an improper rational function splits into a polynomial plus a proper part via polynomial division. Irreducible quadratics are the ones that refuse to factorise over the reals, like x2+4 or x2+x+1; they are the reason tan−1 shows up in the answers.
Before the general strategy, a warm-up that revises the two key tactics for irreducible quadratic denominators.
Example. Evaluate ∫x2+2x+10xdx.
The first tactic is to force the derivative of the denominator (2x+2) onto the numerator:
Every proper rational function with an irreducible quadratic denominator is integrated exactly like this; part of it becomes a ln and the rest becomes a tan−1.
If the rational function is improper, use polynomial division to write f as a polynomial plus a proper rational function. The polynomial is trivial to integrate, so we only ever need to worry about proper rational functions.
Every proper rational function can be written as a unique sum of functions of the form
(x−a)kA and (x2+bx+c)kBx+C,
where x2+bx+c is irreducible. This sum is called the partial fractions decomposition of f.
3. Integrate each term of the decomposition using (after completing the square or a simple substitution) the standard formulae
To find the decomposition of a proper rational function qp, factorise the denominator q as far as possible into real linear factors and real irreducible quadratic factors; the factorisation determines the form of the decomposition, and then the constants are found by algebra. There are a few cases.
Case 1: distinct linear factors. Each factor contributes one term with a constant on top:
The numerator over an irreducible quadratic is Bx+C, not just a constant; forgetting the Bx is a classic mistake.
Example. Find the partial fractions decomposition of (x+1)(x2+x+1)4x2+2x+1.
The quadratic x2+x+1 has discriminant 1−4=−3<0, so it is irreducible and the decomposition takes the form
Case 4: repeated irreducible quadratic factors. The pattern combines Cases 2 and 3: each power gets a linear numerator, e.g.
(x2+9)3x2+x=x2+9Ax+B+(x2+9)2Cx+D+(x2+9)3Ex+F.
This case basically never shows up in first year (way too much arithmetic), so knowing the form is enough.
Example. Write down the form of the partial fractions decomposition of
x3(x−7)(x2+3)2(x2+x+2)4x4−3x2+x−9.
(No need to evaluate the constants.) The repeated linear factor x3 contributes three terms, the distinct linear factor x−7 contributes one, (x2+3)2 contributes two linear-numerator terms and the irreducible x2+x+2 (discriminant 1−8<0) contributes one:
Before writing down the form of a decomposition, check that the denominator is completely factorised and that every quadratic factor really is irreducible; x2−4 is not irreducible — it factorises as (x−2)(x+2) and contributes two linear terms, not a Bx+C term.
Do not forget the 21 in ∫2x+1dx=21ln∣2x+1∣+C; the derivative of 2x+1 is 2, not 1.
Example. Find ∫(x−5)(x2−4x+13)4x2−15x+29dx.
The integrand is proper and the denominator is completely factorised (x2−4x+13 has discriminant 16−52=−36<0, so it is irreducible), so we go straight to the decomposition:
The first term x−53 integrates immediately to 3ln∣x−5∣, so we focus on the second. Writing x+2=21(2x−4)+4 to get the derivative of the denominator on top,
Notice how all three standard forms (power rule aside, ln and tan−1) show up in the one integral; that is the typical exam experience.
Example. Find ∫x2−1x2+1dx.
It is tempting to jump straight to partial fractions, but the numerator and denominator have the same degree, so the integrand is improper and we must divide first:
x2−1x2+1=1+x2−12.
Also note that x2−1 is not irreducible, so no tan−1 will appear; instead we decompose
An integrand whose numerator and denominator have equal degrees is still improper; always compare degrees before decomposing. Compare this with ∫x2+1dx=tan−1x+C; a single sign in the denominator completely changes which standard form you land on.
Since we can now integrate any rational function, a sound plan of attack for a 'non-standard' integral is to hunt for a substitution that converts it into the integral of a rational function. These are called rationalising substitutions. There is no recipe for choosing a good one; you develop a feel for it with practice, but the guiding principle is: substitute away the ugliest part of the integrand (a fractional power, a square root, an exponential) in one hit.
Example. Evaluate ∫1+x1/4dx.
The aim is to replace the fractional power x1/4 with something usable, so let x=u4, dx=4u3du:
∫1+x1/4dx=∫1+u4u3du,
which is a rational function (improper, so divide). Rather than long division, notice that
If several fractional powers appear, take u to the lowest common multiple of the denominators of the exponents; e.g. for ∫x1/3+x1/4x1/2dx the LCM of 2,3,4 is 12, and x=u12 turns it into 12∫u+1u14du, which polynomial division handles.
Example. Evaluate ∫e2x−1dx.
One option is u=ex, which leads to ∫uu2−1du and then a u=secθ or u=coshθ substitution on top — it works, but it is slow. The better approach removes the square root in the very first substitution: let u2=e2x−1. Differentiating both sides,
When the integrand is a rational function of sinx and cosx (things like 5+4cosx1, where none of the 2.1 tricks apply), the half-angle substitution — sometimes called the Weierstrass substitution — is guaranteed to produce a rational function of t.
Note
Theorem (t=tan2x identities) If t=tan2x, then
sinx=1+t22t,cosx=1+t21−t2,dx=1+t22dt.
Proof. Since sec22x=1+tan22x=1+t2, we have cos22x=1+t21. The double angle formulae then give
and differentiating t=tan2x gives dxdt=21sec22x=21(1+t2), i.e. dx=1+t22dt. ■
Basically, every trigonometric function of x is a rational function of tan2x, so this substitution always rationalises the integral. The price you pay is that the algebra can get heavy, so treat it as the last resort once the simpler tricks have failed.
Often several substitutions will work on the same integral, and part of the skill is picking the cheapest one.
Example. Evaluate ∫01(4+x2)5/2x3dx. The substitution table suggests x=2tanθ or x=2sinhθ, and a rationalising substitution u2=4+x2 would also work. But the humble u=4+x2 is best here: the odd power x3=x2⋅x hands you the spare x that du=2xdx needs, and x2=u−4 mops up the rest. Converting the limits (x=0⟹u=4, x=1⟹u=5),
Therefore, the integral equals 7525−115. For comparison: x=2tanθ eventually reduces the integrand to 21sin3θ, which needs the odd-power trick from 2.1 and a limit conversion; it gets the same answer with about triple the work. Before reaching for a trigonometric or hyperbolic substitution, check whether an ordinary u-substitution already works; an odd power of x next to a function of x2 is the classic giveaway.
The real exam skill is not executing any single method, it is diagnosing which one applies. Cover the solutions and classify each of the following before evaluating it.
Example. Evaluate each of the following integrals. (i).∫1−x2xdx (ii).∫1−x2x2dx (iii).∫x2+2x+5x+3dx (iv).∫sin2xcos3xdx (v).∫1+xdx
For (i). the x on top is (up to a constant) the derivative of 1−x2, so despite the 1−x2, no trigonometric substitution is needed — an ordinary u-substitution does it. With u=1−x2, du=−2xdx:
∫1−x2xdx=−21∫u−1/2du=−u+C=−1−x2+C.
For (ii). the numerator is now x2, which cannot pair up with dx, so the u-substitution fails and we genuinely need x=sinθ, dx=cosθdθ:
converting back with the usual triangle (sinθ=x, cosθ=1−x2). Compare (i) and (ii) carefully; one power of x is the entire difference between a one-line u-substitution and a full trigonometric substitution.
For (iii). the denominator has discriminant 4−20=−16<0, so it is an irreducible quadratic: split off the derivative of the denominator, then complete the square. Writing x+3=21(2x+2)+2 and x2+2x+5=(x+1)2+22:
The pattern to internalise: look for a derivative pair (for a plain u-substitution) first; surds of quadratics go to trigonometric or hyperbolic substitutions; rational functions go to partial fractions, dividing first if improper; products of sines and cosines go to the product-to-sum identities; fractional powers and roots go to rationalising substitutions; and a rational function of sinx and cosx goes to the t=tan2x substitution as a last resort.